Ferhad Kaleli
Co-Founder
Ferhad Kaleli is a mechanical engineer and co-founder of Robsen Robotics. He has worked with industrial robots since 2011 and co-founded the company in 2013, at twenty-four. Today, he leads a team that has commissioned more than 200 robotic cells across machine tending, die casting, surface finishing, assembly, quality control, and machine vision. His work spans robotics, manufacturing processes, and investment planning. When discussing a new project, he likes to understand how the proposed cell fits into the wider production process, what the customer needs it to deliver, and how those needs might change over time. Over the years, he has visited hundreds of production plants. Those visits, and the conversations with the people running them, continue to shape his approach to engineering and leading his team. He attends leading robotics conferences around the world, with a practical interest in where new technologies can be useful and how well they hold up in day-to-day production. Conversations with Ferhad often start with a specific application and turn into a broader discussion about manufacturing, robot technology, and investment decisions. His writing for The Robotic Note draws on these conversations and his experience on the factory floor. He holds bachelor’s and master’s degrees in mechanical engineering from Istanbul Technical University, where he is currently pursuing a doctorate.
#robotics#automation#machinevision
Articles by Ferhad Kaleli
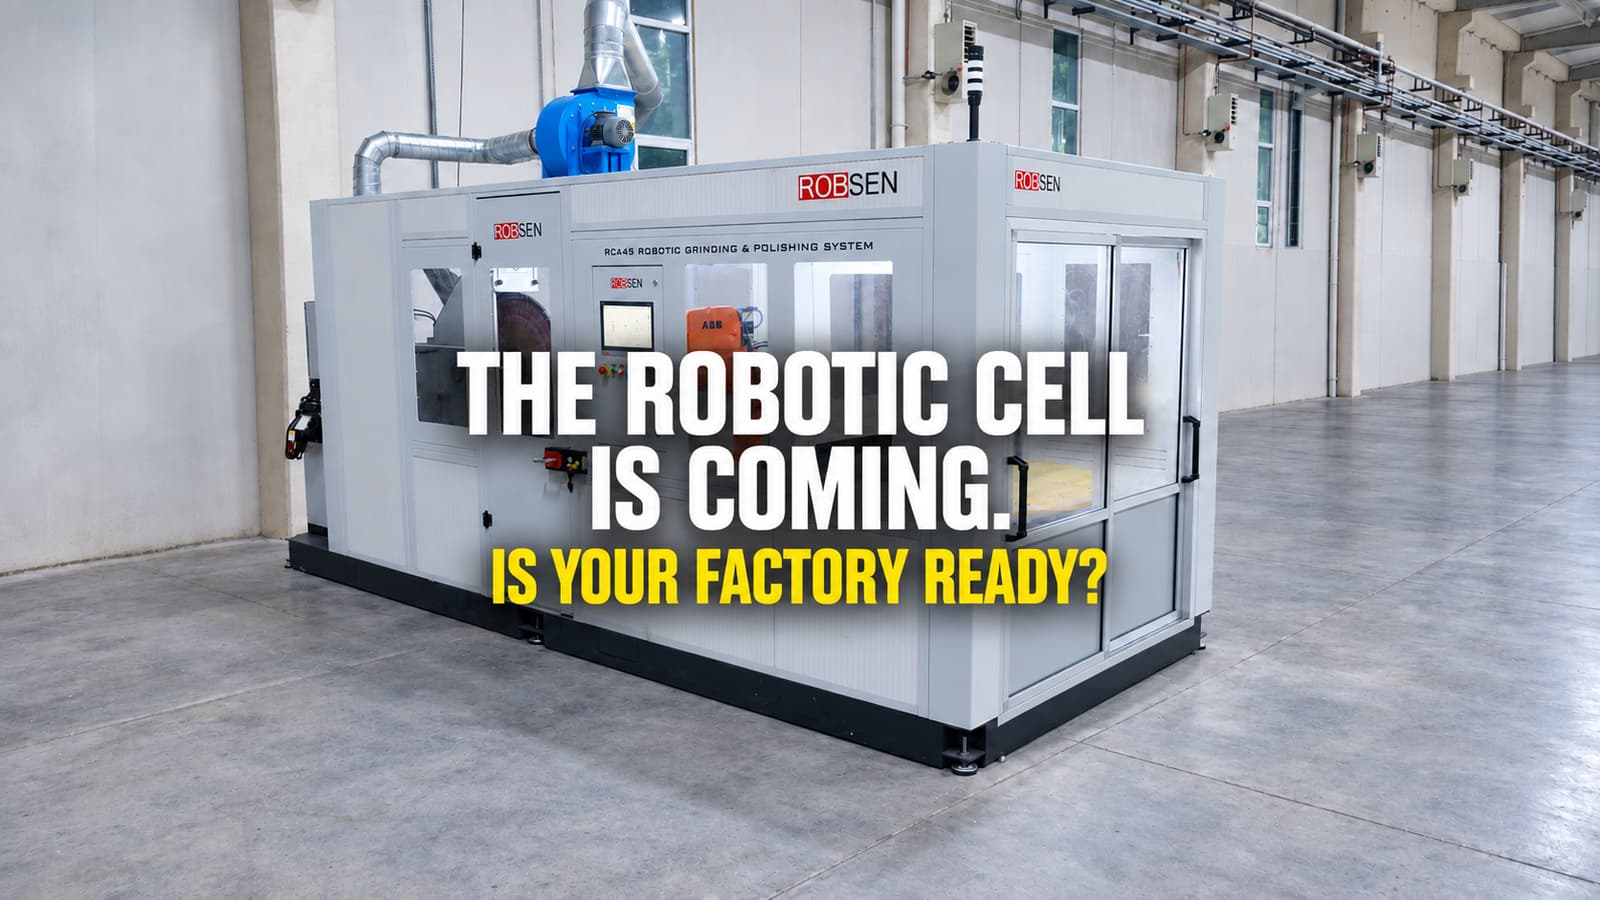
What Must Be Ready Before the Robot Cell Arrives?
Fixtures, setup times, training and internal communication all affect how quickly a new robot cell becomes reliable production.
Before You Request a Robot Cell Quote, Define the Project
Learn how to choose the right first automation process and prepare a robot-cell specification that produces comparable, technically meaningful quotations.
Working With Your Robot Integrator: From Order to Long-Term Support
Deciding on a robot investment and setting the budget aside does not mean you are ready for it. What the months after the order tell you about the partner you chose.
Choosing a Robot Integrator: What Should You Look For?
The equipment list and the price are visible on the page. The experience behind a robot proposal takes more conversation to understand — here is what to look for before you choose an integrator.
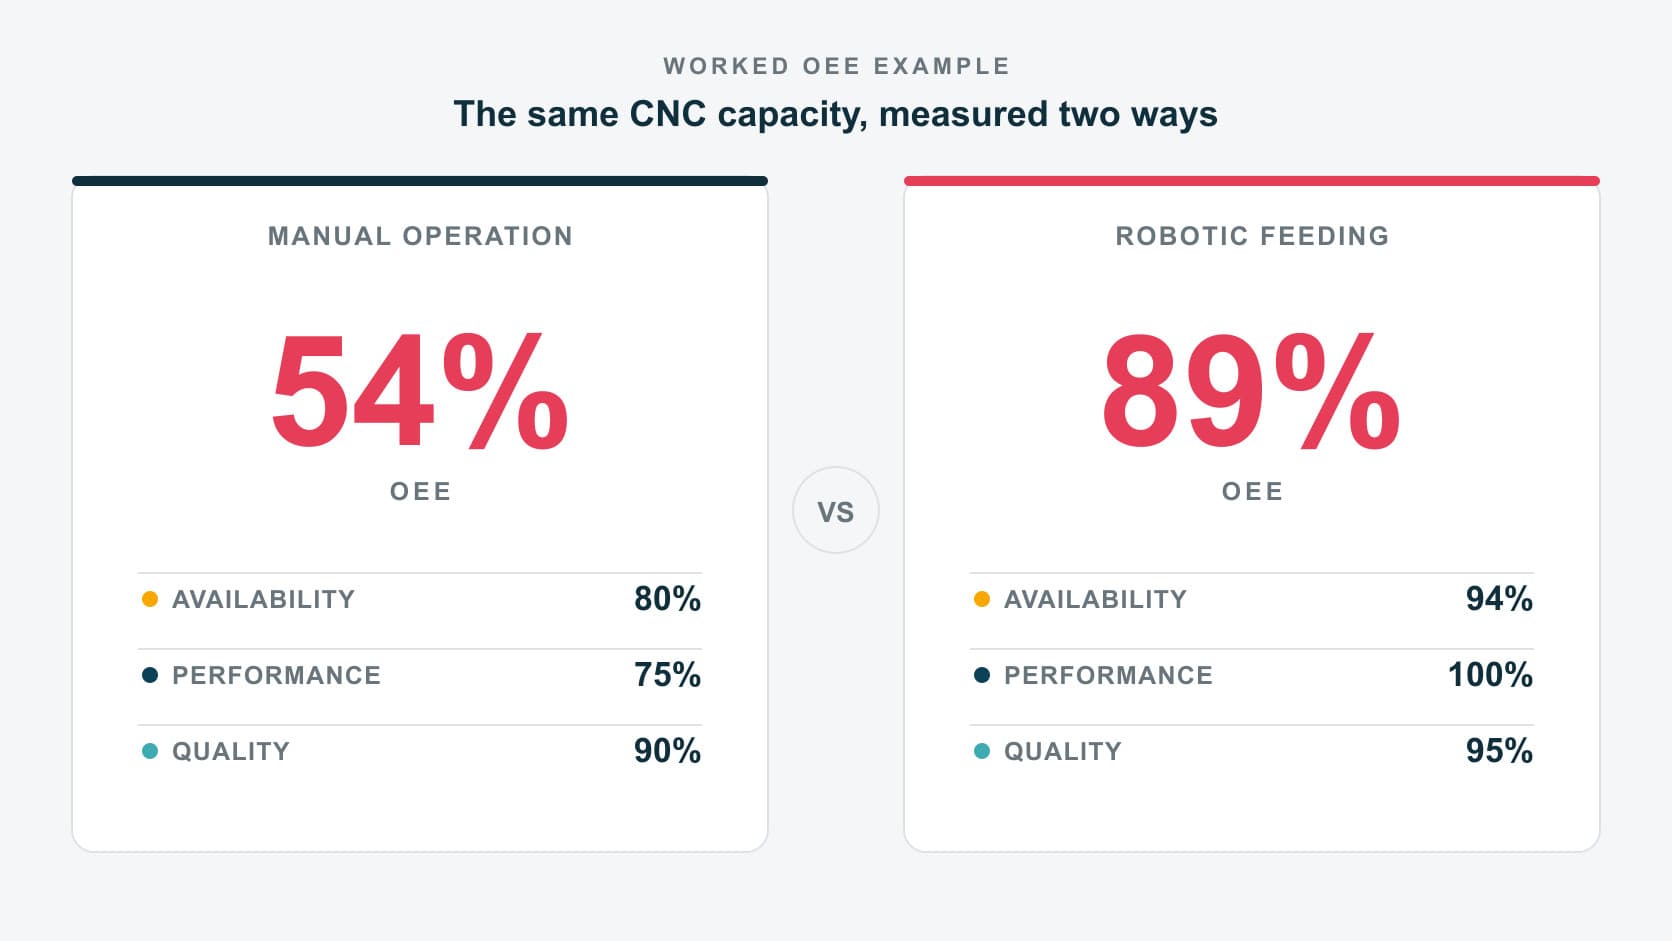
What Changes When a Robot Feeds the CNC?
Using the same CNC and the same 500-minute period, this worked example shows which losses robotic tending can reduce—and which losses remain.
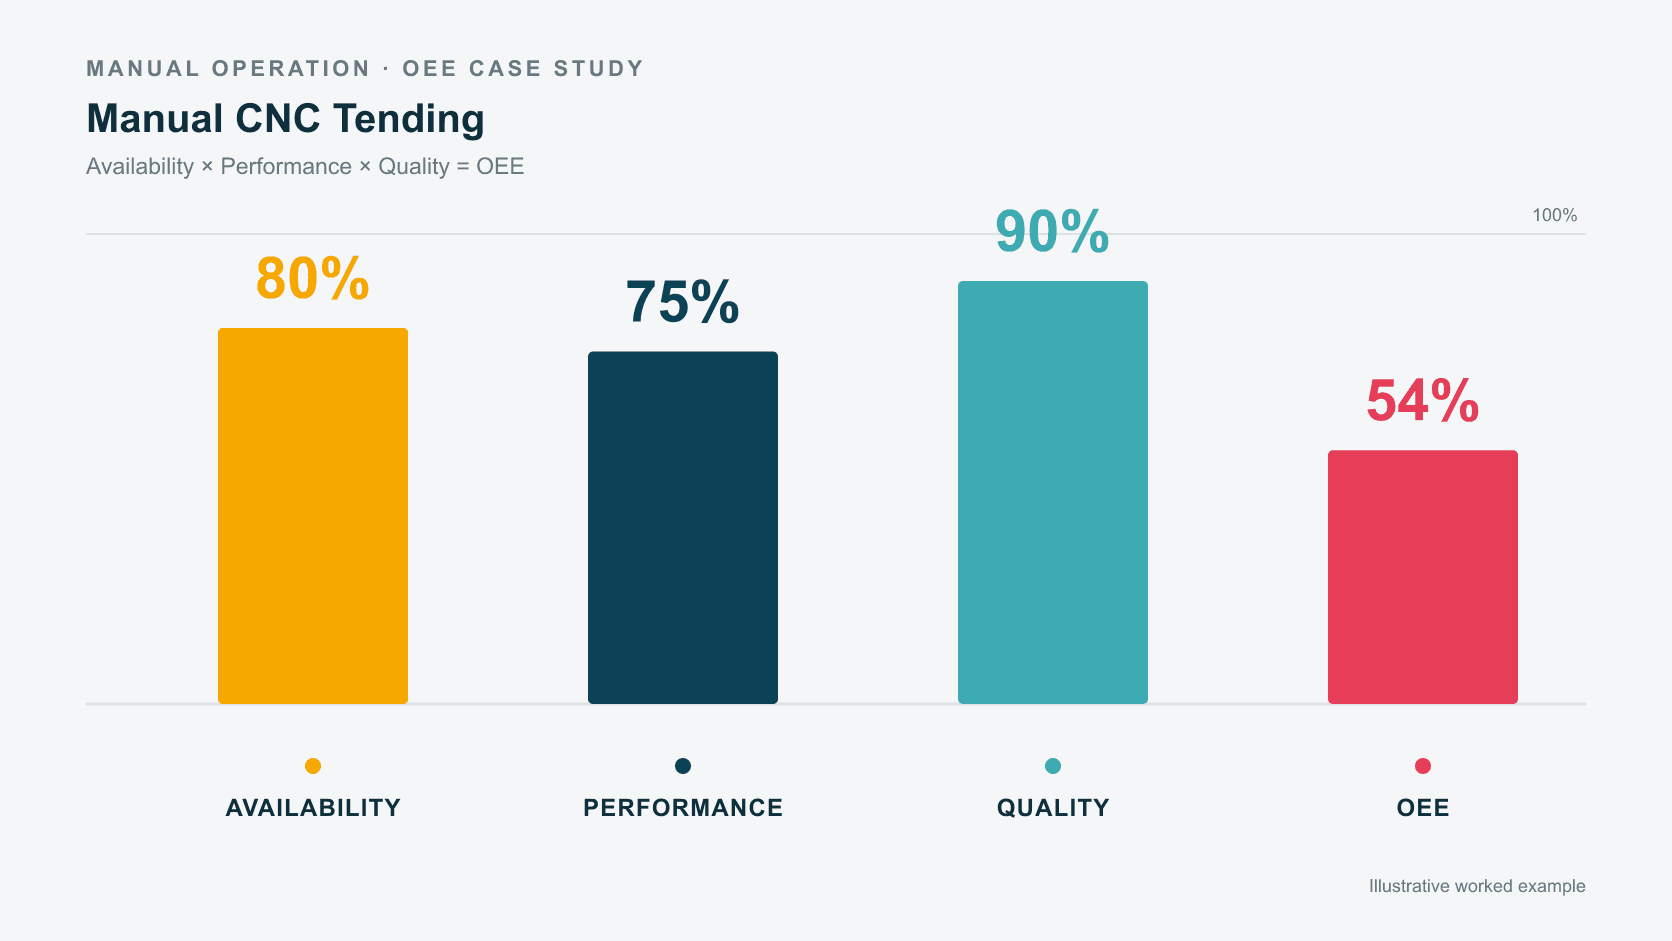
Your CNC Machines Are Running. But Are You Using Their Full Capacity?
A worked CNC OEE example shows why visible activity does not prove full capacity—and why measurement should come before another machine investment.
A stopped machine costs more than the parts it didn't make
Manufacturing downtime costs more than lost output. How indirect losses, weak production data and missed capacity quietly reduce margins — and the three fixes, in the order they actually work.
You may have the capacity. Can you prove it?
Nominal capacity is not the capacity you can promise. See how missing cycle, labor and stop-reason data hide usable CNC capacity — and which records close the gap.